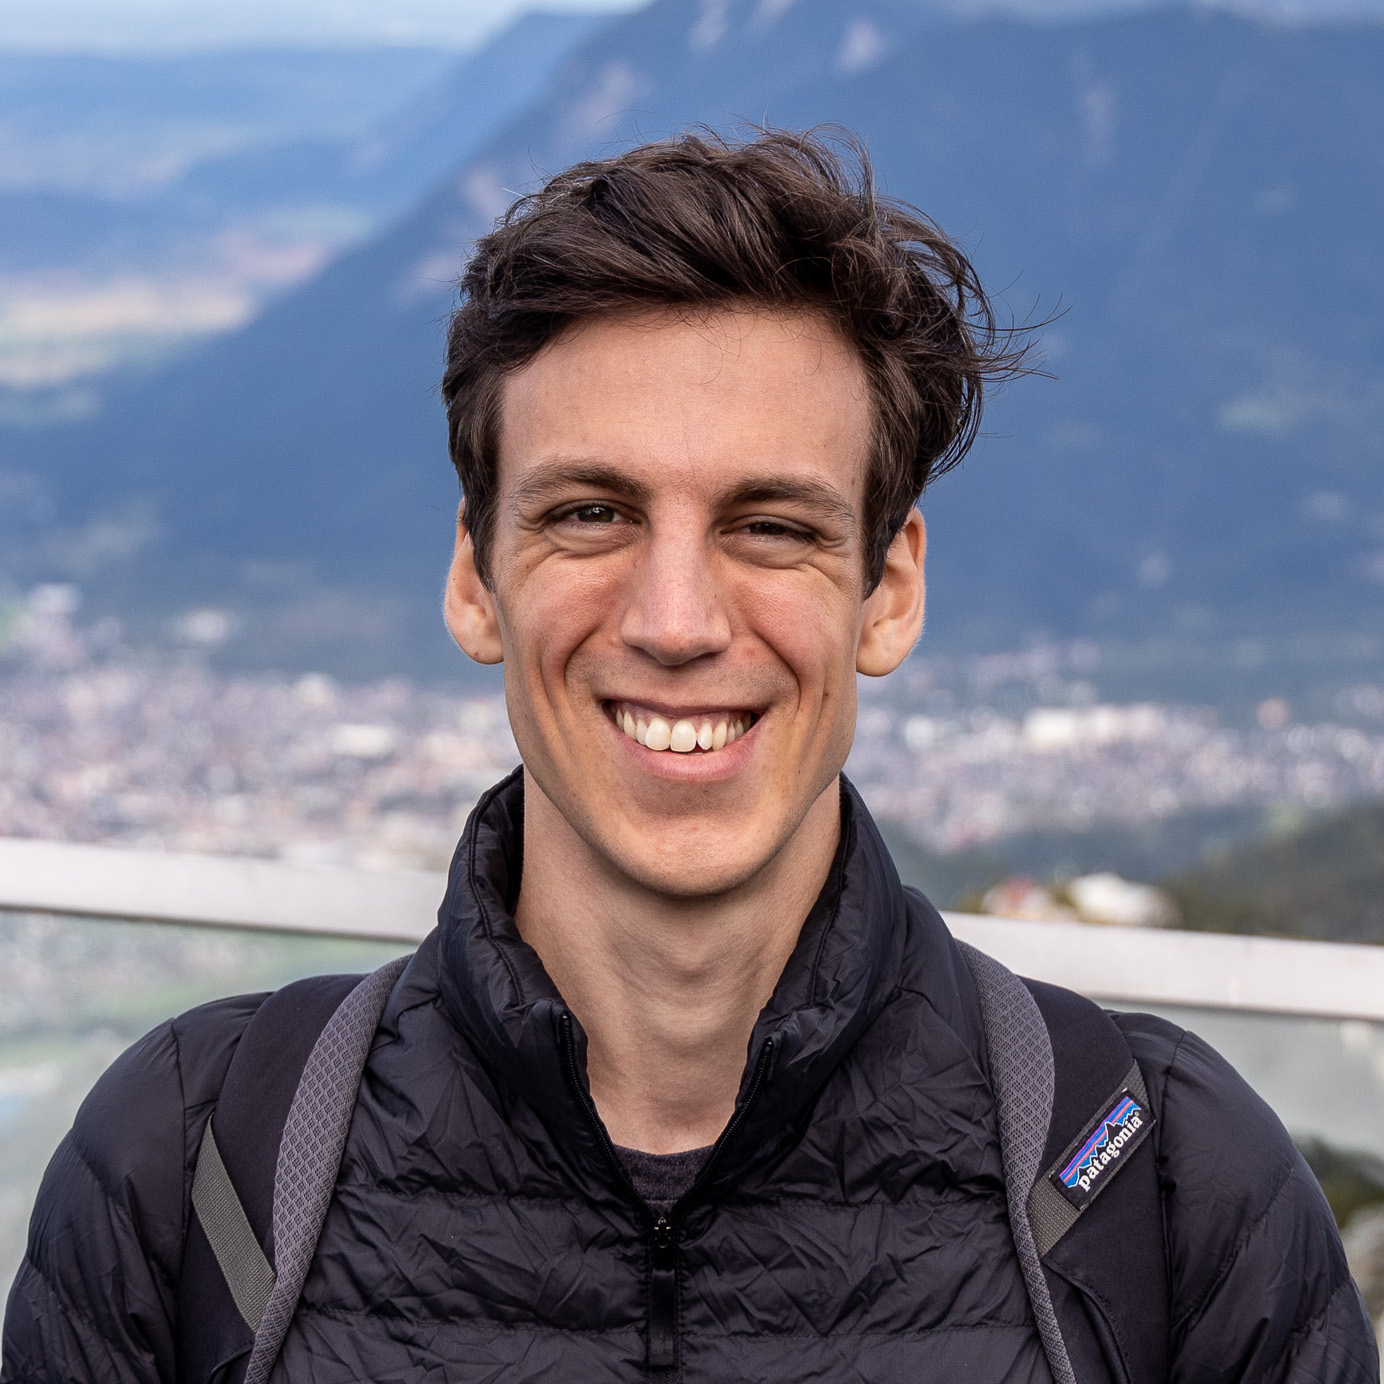
Arek Sredzki

Autonomy Engineering Leader
End-to-End Driving Policy & Motion Planning

Contact Me

Personal Profile

My passion is improving the world by appyling advanced robotics and machine learning to impactful challenges.

profile


I'm a hard-working and enthusiastic individual who strives for excellence and thrives in fast paced environments. I have proven experience in safety-critical fully autonomous systems as a leader and individual contributor.

Experience

Tesla

Senior Staff Autopilot Engineer / Autopilot Manager / Feb 2023 - Aug 2026

  • Led the Destination & Special Behaviors team within Autopilot (5 direct reports) while remaining one of the most prolific individual contributors to the end-to-end driving policy model.
    • Built the team from the ground up, hiring most of its members. Recognized with multiple performance grants and Top Talent awards.
  • End-to-End Trip Autonomy (FSD v14): Introduced reversing and gear changes to the driving policy model, making it broadly capable of unparking and K-turns, and launched configurable Arrival Options (Driveway, Charger, Street, Parking Lot). Enabled zero-intervention trips in which the vehicle unparks and parks according to each user's preference.
  • Actually Smart Summon (shipped Sept 2024): Led the complete product design and engineering, working with vehicle software, UI, and mobile teams. Customer vehicles drive themselves, unoccupied, to their owner within a 100 m radius on private roads. Rolled out to most HW3/HW4 vehicles globally.
    • Owned the driving policy: capable and safe, with zero safety issues across millions of sessions.
    • In 2026, unified the FSD and Summon models on HW4 and shipped to Cybertruck.
  • Robotaxi: Core contributor from the Cybercab unveil (We, Robot, 2024: live rides between multiple destinations on a closed course), through the first driverless rides on public roads (Jan 2026, since expanded to multiple cities), to Cybercabs with no steering wheel or pedals on public roads (Aug 2026).
  • Driving Policy Model: Shipped a sustained, high-volume stream of improvements to the production end-to-end model across architecture, training data quality, and new datasets and evaluations. Most recently drove development of next-generation reasoning capabilities targeting the hardest remaining failure modes such as complex or unreachable destinations, blocked roads, and incorrect navigation.

Argo AI

Staff Software Engineer / Software Engineering Manager II - Motion Planning - Trajectory Selection & Remote Guidance / August 2019 - Nov 2022

  • Led the Trajectory Selection & Remote Guidance team within Motion Planning (10 direct reports)
    • Highly regarded leader with excellent rapport with all direct reports and a mentor to many on other teams. Perfect eNPS scores for Growth, Management Support, and Recognition.
  • Responsible for analyzing the desirability of each proposed AV candidate trajectory and selecting the optimal one considering safety, comfort, and other factors.
  • Pioneered a movement to increase novel candidate trajectory diversity throughout the planning stack, greatly expanding the AV's ability to appropriately evaluate complex interactions.
  • Designed, implemented, and iterated on the system for object interaction risk evaluation.
  • Drove the effort to incorporate Deep Learning into Motion Planning for evaluating human-likeness and contributed to successful and accelerated deployment in the fleet.
  • Frequently contributed very high-impact self-motivated projects (select examples from 2022Q3):
    • Reduced the runtime of every simulation by 73s, reducing simulation costs by 25%.
    • Optimized in-house serialization codegen to reduce single build-unit compile times by up to 7.5mins, reduced overall vehicle software binary sizes by 15%.
    • Reduced overall post-simulation metrics evaluation runtimes by 35%.
    • Redesigned the org-wide profiling library, removing lock contention and undue overhead.
  • Led the cross-functional development of the Remote Guidance platform with a focus on integration into the autonomy stack. Deployed 13 guidance features and 7 request detectors.
    • Successfully mitigated 2000 interventions per month.
  • Developed onboard/offboard metrics and dashboards used to enable fleet-driven program management and inform project priorities.
  • Co-architected the next-generation visualization framework based on Magnum Graphics and ImGui.
    • Drastically reduced the development effort needed for improved system introspection (~5x).
    • Improved rendering runtime performance by ~10x & enabled compelling modern visual effects.
    • Provided a pathway for tools to be transpiled for web-based deployment using WASM.

NIO

Senior Autonomous Controls Engineer - Path/Motion Planning / August 2017 - August 2019

  • Developed an efficient, real-time-safe robotics software framework and middleware that replaced ROS in the L4 system.
    Created rich developer-facing tooling for real-time diagnostics as well as data recording, replay, processing, and visualization, enabling teams to iterate at a rapid pace
  • Architected and implemented many of the core L4 stack libraries
  • Acted as the de facto software engineering/C++ expert for all AD/AI SW teams
  • Optimized algorithm designs and implementations across the full AD stack
  • Designed and implemented the base object fusion solution (multi-modal, multi-target)
  • Established and co-managed the L4 SW testing release process

Google

Software Developer Intern / May - August 2016

  • Contributed to improving Chrome Autofill for 100M+ users
  • Refined global compatibility with improved pattern matching for element detection
  • Created an automated integration testing suite for Autofill in Chrome
    • Removed the need for tedious manual reliability/website compatibility testing
  • Experimental investigation of future directions for Autofill
    • Prototyped a next-gen automated checkout solution during an internal two-day hackathon

Tesla Motors

Software Engineering Intern / January - April 2016

  • Co-developed a new CAN requirement spec. format for company-wide usage w/ Model 3
    • Replacement for DBC, designed for data de-duplication, flexibility, and auto-optimization
  • Created a fully-featured JCAN editor application (Canode), used by all firmware teams
    • Natively multi-platform, fully asynchronous, loosely coupled and highly cohesive
    • Provides instantaneous bus analysis results and input feedback for improved workflow
    • Automatic updates served by a full-featured release server
  • Advised on and enabled data driven decision-making for Model 3 CAN architecture
  • First week: built and deployed a release artifact service with LDAP authenticated web app

UBC Sailbot Team

Software Lead / September 2013 - July 2017

Highlights

  • Record for the furthest fully autonomous boat crossing of the Atlantic Ocean
  • Won the International Robotic Sailing Regatta in 2014, 2013, and 2012
  • Optimal real-time motion planning with dynamic obstacles in the complex sailing domain
  • Efficient, optimal global path planning considering weather data for performance and risk
  • Created a novel marine obstacle detection system using computer vision applied to thermal imaging
  • Developed a fully redundant sensor system with intelligent failure-resistant firmware
  • Power management for an embedded system, accounting for solar charging
  • Managed a 17-person software team with Agile methods (Scrum)

Next Generation System Overview

  • Industry-standard hardware architecture
  • Distributed real-time control system connected over CAN
  • Navigation system on Nvidia Jetson TX1 (same processor as the Drive PX 2)
  • Intelligent power system with on-board solar charging
  • Server-side planet-level path planning with dynamic risks (forecasted weather)
  • Real-time "global" and "local" motion planning with dynamic obstacles (trajectory prediction)
  • DNN for computer vision applied to both infrared and visible light for long-range obstacle detection
  • Resilient close range object recognition using LiDAR
  • Robust sensing system with anomaly detection, sensor fusion and hardware failure redundancy
  • 3x redundant networking (SBD Satellite, LTE/3G, Wi-Fi)
  • Simulation for validation and neural net training

Vikom Media

Lead Developer & Founder / September 2011 - Present

  • Built Telltale, Disk Map and Tabby (see Apps)
  • Reached 2.5 million unique users in 5 months with an MVC web app (AdCraft.co 2011)
  • Created and deployed a fast, scalable and responsive image sharing website
  • PostgreSQL & MongoDB optimization and management
  • Long-term software consulting to Water Wall Turbine Inc. (Web Development / Graphics)
  • Operating a registered business and negotiating deals with client organizations

Vparq

CTO & Co-Founder / May - August 2015

  • Designed a distributed stack consisting of Angular.js, Node.js, PostgreSQL, Redis
  • Created a responsive real-time single page application using Angular.js and Socket.io
  • Allowed for scalable deployment with a stateless RESTful API backend using JWT authentication

BridgeWater Lines

Advising on AI powered safety features

Empowering Novel Marine Commuting.

Apps

Products I've built and run through Vikom.

Telltale icon

Telltale

AI weather & routing

A performance analytics and sharing platform for instrumented sailboats.

  • World-class AI weather predictions
  • Routing for wind, current and waves
  • Performance analysis for every sail
  • Share instruments and location live
Visit telltaleapp.ca
Disk Map icon

Disk Map

Free for Mac

A native macOS app that shows what is filling your disk and frees space safely.

  • Every folder as a map
  • A Space Advisor for the safest steps
  • Private: nothing leaves your Mac
Visit diskmap.app
Tabby icon

Tabby

Free for Chrome

AI-powered tab management that keeps your browser tidy.

  • Smart grouping and duplicate finding
  • Session recovery if Chrome closes
  • On-device AI; your data stays local
Visit get-tabby.ca

Education


University of British Columbia

Bachelor of Science - Computer Science - Sept. 2013 - July 2017

Top Oral Presentation – UBC Multidisciplinary Undergraduate Research Conference, 2015

In addition to being the Software Lead at UBC Sailbot (see below), I'm actively involved in graduate level research involving motion planning and obstacle detection.

Coursera

Intro to Machine Learning – Andrew Ng - Summer 2015

Udacity

Artificial Intelligence for Robotics – Sebastian Thrun - Summer 2014

Resume

My resume can be found here

Contact

Interested? Please contact me and I'll get back to you asap.

   Vancouver, BC, Canada

   +1 (672) 515-3175

Misc. Experiments

Autofill Smoke Tests